|
| Research article - (2026)25, 822 - 837 DOI: https://doi.org/10.52082/jssm.2026.822 |
| Movement Regularity and Local Dynamic Stability During Acute and 12-Week Retrained Non-Rearfoot-Strike Running Compared to Habitual Non-Rearfoot-Strike Running |
Kaicheng Wu1, Liqin Deng1,2, Xini Zhang3, Bokai Suo1, Zeyu Lu1, Jiaze He4, Fan Yang5, Weijie Fu4, |
|
Narrated in English
|
 |
| Key words: Foot strike pattern, running biomechanics, gait retraining, sample entropy, largest Lyapunov exponent |
| Key Points |
|
|
|
| Participants |
A simulation-based sample-size analysis was conducted using the random-intercept linear mixed-effects model specified for the primary analysis (Outcome ~ State + (1 | participant) (Green and MacLeod, |
| Procedure |
During the first laboratory visit, participants ran naturally on a treadmill while wearing the experimental shoes (Nike Pegasus 34, 285 g, size 43, heel-to-toe drop: 12 mm). Their habitual foot-strike patterns were recorded in the sagittal plane using the slow-motion video mode of an iPhone 12 Pro at 240 frames·s⁻1 and were classified frame by frame according to the foot position at initial ground contact, following the criteria described by Hasegawa et al. ( Before formal testing, HRFS participants completed an individualized familiarization period at the testing speed, during which they practiced the intended NRFS pattern. Familiarization continued until they verbally reported feeling comfortable maintaining the pattern (Valenzuela et al., A total of 36 retro-reflective markers (14 mm diameter) were placed bilaterally on the following anatomical landmarks: anterior superior iliac spine, posterior superior iliac spine, iliac crest, and greater trochanter (pelvis); medial and lateral femoral condyles (knee); medial and lateral malleoli (ankle); and 1st and 5th metatarsal heads, distal phalanx of the hallux, and calcaneus (foot). In addition, rigid clusters that consisted of 3 noncollinear markers were affixed onto the lateral thigh and shank of each leg. During formal testing, the participants ran at 9 km·h⁻1 on an instrumented treadmill (Bertec FIT, USA) while wearing the experimental shoes. The HRFS participants were instructed to adopt NRFS acutely (HRFS-AN), while HNRFS runners maintained their natural strike pattern. Data collection began only after an investigator visually confirmed a stable running pattern, operationally defined as maintaining the intended foot-strike pattern without observable abrupt changes in step frequency or stride length. Data were then recorded for 30 s. Marker trajectories were captured using an eight-camera Vicon T40 system (Oxford Metrics, UK) at 200 Hz. The HRFS participants who completed the 12-week GR protocol returned for post-tests, during which they ran with their self-selected post-training strike pattern (HRFS-GR). Data collection procedures were identical to those of baseline testing. |
| Training protocol |
HRFS runners voluntarily completed a 12-week GR program designed to promote the adoption of NRFS. Minimalist shoes (Vibram FiveFingers; 3 mm rubber outsole, no midsole, zero heel–toe drop; minimalist index: 92%) were used to simulate barefoot running while providing plantar protection. Training volume was progressively increased based on individual weekly mileage (Lieberman et al., |
| Data processing | ||
Kinematic data and vGRFs were processed using Visual3D (C-Motion, Inc., Rockville, MD, USA). Marker trajectories were low-pass filtered using a fourth-order Butterworth filter at 7 Hz, and vGRF signals were filtered at 50 Hz (Deng et al., Joint angles were calculated using Euler angles between adjacent segments. Foot strike angle was defined as the angle between the line that connected the first metatarsophalangeal joint and calcaneus markers and the global anterior–posterior axis, offset by the corresponding angle measured during static standing (Altman and Davis, Vertical average loading rate (VALR) and vertical instantaneous loading rate (VILR) were calculated from vGRF during early stance. A point of interest (POI) was defined as the point immediately before the vGRF slope decreased below 15 body weights per second, with the additional requirement that vGRF magnitude exceeded body weight (Futrell et al., Discrete variables were extracted from 10 consecutive gait cycles and averaged for statistical analysis. Within-subject variability of the discrete joint angle measures was quantified using the coefficient of variation (CV) and calculated as the standard deviation (SD) divided by the mean across the 10 gait cycles. Regularity and complexity of movement were quantified using SampEn, computed from the continuous joint angle time series of the hip, knee, and ankle in the sagittal, coronal, and transverse planes (McCamley et al.,
where Local dynamic stability was evaluated using the largest Lyapunov exponent (LyE), calculated from the ten cycles of running time series of right hip, knee, and ankle joint angles in the sagittal, coronal, and transverse planes, as well as from the COM position time series (
where |
| Statistical analysis |
All outcomes are reported as mean ± SD. For each outcome, a random-intercept linear mixed-effects model (LMM) was fitted, with participant included as a random effect to account for the repeated observations in the HRFS participants. A three-level group–condition factor, hereafter termed State, was included as a fixed effect, with levels HRFS-AN, HRFS-GR, and HNRFS. State represented the three observed group–condition combinations rather than three independent participant groups. The model was specified as: Outcome ~ State + (1 | participant) For each outcome, the linear mixed-effects model evaluated the overall effect of State and the following three contrasts: HRFS-GR minus HRFS-AN, HNRFS minus HRFS-AN, and HNRFS minus HRFS-GR. The |
|
|
| GR dropout |
A total of 19 RFS runners enrolled in GR, 2 discontinued due to triceps surae soreness, and 1 was excluded for repeated protocol nonadherence. Subsequently, 16 completed the post-intervention test, while 3 failed to convert to NRFS, and thus, were excluded, leaving 13 participants (age: 34.2±8.6 years; body mass: 70.0±8.5 kg; height: 1.73 ± 0.07 m) in the HRFS-GR group for analysis. |
| Spatiotemporal, foot strike angle, and ground reaction force parameters |
All three observed states were classified as NRFS, with mean foot strike angles below 8°. A significant overall effect of State was observed for foot strike angle (p < 0.001, Significant overall effects of State were also observed for VILR (p = 0.028) and VALR (p = 0.025). Compared with HRFS-AN, HRFS-GR exhibited higher VILR (MD = 17.32 BW/s; p = 0.012) and higher VALR (MD = 14.93 BW/s; p = 0.016). Neither VILR nor VALR differed significantly between HNRFS and HRFS-AN or between HNRFS and HRFS-GR (all p > 0.05). No significant overall State effects were observed for cadence, step length, contact time, or vGRF (all p > 0.05; |
| Discrete variables |
At the knee, HRFS-GR exhibited lower CV values than HRFS-AN for the sagittal-plane minimum angle (MD = −0.09; p = 0.008), sagittal-plane ROM (MD = −0.14; p = 0.002), transverse-plane maximum angle (MD = −0.19; p = 0.049), and transverse-plane ROM (MD = −0.07; p < 0.001). At the ankle, the sagittal-plane maximum angle CV was lower in both HRFS-GR (MD = −0.35; p = 0.005) and HNRFS (MD = −0.35; p = 0.005) than in HRFS-AN. HRFS-GR also exhibited lower sagittal-plane ROM CV (MD = −0.13; p = 0.036) and transverse-plane ROM CV (MD = −0.10; p = 0.034) than HRFS-AN. No significant overall State effects were observed for the remaining joint-angle or COM CV parameters (all |
| SampEn |
At the hip, a significant overall effect of State was observed for transverse-plane SampEn (p = 0.012). HRFS-GR exhibited higher SampEn than HRFS-AN (MD = 0.07; p = 0.012), while HNRFS exhibited lower SampEn than HRFS-GR (MD = −0.05; p = 0.050). At the knee, a significant overall State effect was also observed for knee sagittal-plane SampEn (p < 0.001). Compared with HRFS-AN, SampEn was lower in HRFS-GR (MD = −0.02; p = 0.004) and HNRFS (MD = −0.05; p < 0.001). HNRFS also exhibited lower SampEn than HRFS-GR (MD = −0.03; p < 0.001). At the ankle, a significant overall State effect was observed for sagittal-plane SampEn (p < 0.001). SampEn was lower in HRFS-GR (MD = −0.04; p = 0.002) and HNRFS (MD = −0.05; p = 0.002) than in HRFS-AN, whereas HRFS-GR and HNRFS did not differ significantly. For the COM, a significant overall State effect was observed for vertical SampEn (p = 0.002). Vertical COM SampEn was lower in HRFS-GR (MD = −0.01; p = 0.014) and HNRFS (MD = −0.03; p = 0.014) than in HRFS-AN, with no significant difference between HRFS-GR and HNRFS. No significant overall State effects were observed for the remaining joint or COM SampEn outcomes (all p > 0.05). |
| LyE |
At the hip, a significant overall effect of State was observed for coronal-plane LyE (p = 0.040). HNRFS exhibited lower coronal-plane LyE than HRFS-GR (MD = −0.24; p = 0.038), while HRFS-AN did not differ significantly from either HRFS-GR or HNRFS. No significant overall State effects were observed for hip sagittal- or transverse-plane LyE. At the knee, a significant overall State effect was observed for sagittal-plane LyE (p < 0.001). Compared with HRFS-AN, sagittal-plane LyE was lower in HRFS-GR (MD = −0.18; p = 0.017) and HNRFS (MD = −0.38; p < 0.001). HNRFS also exhibited lower sagittal-plane LyE than HRFS-GR (MD = −0.20; p = 0.044). No significant overall State effects were observed for knee coronal or transverse-plane LyE. At the ankle, a significant overall State effect was observed for coronal-plane LyE (p = 0.044); however, none of the pairwise comparisons were significant. No significant overall State effects were observed for ankle sagittal or transverse-plane LyE. For the COM, a significant overall State effect was observed for vertical LyE (p = 0.003). Vertical COM LyE was lower in HRFS-GR (MD = −0.14; p = 0.019) and HNRFS (MD = −0.34; p = 0.009) than in HRFS-AN, while HRFS-GR and HNRFS did not differ significantly. No significant overall State effects were observed for COM LyE in the anterior–posterior or medial–lateral directions. |
|
|
This study compared lower-limb kinematics, movement regularity, and local dynamic stability across the HRFS-AN, HRFS-GR, and HNRFS states. The first hypothesis was largely, but not completely, supported: most spatiotemporal and discrete kinematic outcomes did not differ significantly among states, although significant State effects were observed for foot-strike angle, vertical loading rates, selected joint-angle variables, and several CV outcomes. The second hypothesis was supported for selected nonlinear outcomes: compared with HNRFS, HRFS-AN exhibited higher sagittal-plane knee and ankle SampEn, higher vertical COM SampEn, and higher sagittal-plane knee and vertical COM LyE. The third hypothesis was partially supported: HRFS-GR and HNRFS did not differ significantly for most outcomes, but differences remained in selected hip and knee SampEn and LyE measures. All three states had mean foot-strike angles below 8° and were therefore classified as NRFS, indicating that the HRFS participants were able to adopt the intended strike pattern both acutely and after retraining. Cadence, step length, contact time, and peak vGRF did not differ significantly among states, and most discrete joint-angle and COM ROM outcomes also showed no significant differences. These findings are broadly consistent with previous studies showing that habitual rearfoot strikers can acutely reproduce several sagittal-plane kinematic characteristics of habitual forefoot or non-rearfoot strikers (Valenzuela et al., The nonlinear measures further differentiated acute NRFS adoption from retrained and habitual NRFS running. Compared with HRFS-AN, both HRFS-GR and HNRFS exhibited lower SampEn in sagittal-plane knee and ankle and vertical COM movement, together with lower LyE in sagittal-plane knee and vertical COM movement. Given the more pronounced anterior foot strike adopted during HRFS-AN, the higher LyE in these selected trajectories may be compatible with the challenge of acutely adopting a more pronounced and unfamiliar strike strategy. This interpretation is indirectly supported by Ekizos et al. ( SampEn, LyE, and CV should therefore be interpreted as complementary rather than interchangeable measures of movement behaviour (Dingwell et al., Despite the overall similarity between HRFS-GR and HNRFS, residual differences remained in selected nonlinear outcomes. HRFS-GR exhibited higher SampEn in sagittal-plane knee and transverse-plane hip motion and higher LyE in sagittal-plane knee and coronal-plane hip motion than HNRFS. Because HNRFS was an independent cross-sectional reference group rather than the longitudinal endpoint of the HRFS participants, these differences may reflect distinct adaptation histories and between-group characteristics rather than an insufficient retraining duration alone. Importantly, greater similarity to HNRFS should not automatically be regarded as a superior outcome. Movement variability may support adaptability, and its association with musculoskeletal injury remains inconsistent (Baida et al., Although SampEn and LyE cannot establish injury risk, adverse symptoms may occur during the transition to an NRFS pattern, particularly when foot-strike transition is combined with minimalist footwear exposure. In the present study, two participants withdrew during the early retraining phase because of calf and foot pain. Because the intervention also included foot and ankle strengthening exercises, these symptoms cannot be attributed to foot-strike modification, minimalist footwear, or any single intervention component. Nevertheless, these observations support gradual, individually monitored progression during gait retraining. The current study has several limitations. First, nonlinear outcomes may be influenced by methodological choices. SampEn outcomes depend on parameter selection, and although multiple combinations of embedding dimension (m) and tolerance (r) were examined and a representative setting was selected, comparisons are only valid under identical parameter conditions. Likewise, LyE estimates may vary depending on reconstruction settings. However, to reduce methodological bias, LyE was calculated using the same Rosenstein algorithm for all time series, while time delay and embedding dimension were determined for each time series according to established recommendations, the corresponding time delay and embedding dimension values for each parameter have been provided in the Supplementary Material. Second, only male runners were included to improve sample homogeneity and reduce potential confounding effects related to sex-specific physiological fluctuations, which may influence training-load control during the 12-week gait retraining intervention. However, this limits the generalizability of the findings to female runners. Third, although a 12-week GR protocol was adopted, no post-intervention follow-up was conducted. Therefore, the long-term retention of changes in movement regularity and kinematic patterns after removal of external guidance remains unknown. Future studies should incorporate follow-up assessments, and workload monitoring and prospective symptom or injury surveillance, to better clarify the durability and practical significance of GR-induced adaptations during the transition process. |
|
|
Acute NRFS adoption was characterized by a more anterior foot strike than HRFS-GR and HNRFS and lower VILR and VALR than HRFS-GR, whereas peak vGRF and most spatiotemporal and discrete kinematic outcomes were similar among states. Compared with acute adoption, HRFS-GR showed greater regularity in selected knee, ankle, and COM trajectories and greater local dynamic stability in knee and COM motion, broadly resembling the pattern observed in HNRFS. These within-participant changes suggest progressive adaptation to the newly learned NRFS pattern, although selected knee and hip differences remained between HRFS-GR and HNRFS. Overall, the findings suggest that a gradual 12-week gait-retraining program may be an appropriate approach for transitioning habitual rearfoot strikers to NRFS. |
| ACKNOWLEDGEMENTS |
The authors would like to thank all participants for their time and commitment to this study. This work was supported by the National Natural Science Foundation of China (Grant Nos. 12572370 and 12272238) and the Shanghai Oriental Talent Plan Top Talent Project (BJJY2024013). The authors declare that they have no conflicts of interest. All participants provided written informed consent before participation. The study protocol was approved by the Ethics Committee of the University and was conducted in accordance with the Declaration of Helsinki and the current laws of the country in which the study was performed. The datasets generated during the current study are not publicly available but are available from the corresponding author upon reasonable request. All experimental procedures were conducted in compliance with the relevant legal and ethical standards of the country where the study was carried out. The authors declare that no Generative AI or AI-assisted technologies were used in the writing of this manuscript. |
| AUTHOR BIOGRAPHY |
|
| REFERENCES |
|
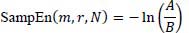


 Altman, A.R., Davis, I.S. (2012) A kinematic method for footstrike pattern detection in barefoot and shod runners. Gait & Posture 35, 298-300.